


Description
Unit DoF6 is a six-axis inertial sensor unit built around the low-power BMI270 IMU. The BMI270 integrates a 16-bit 3-axis accelerometer and a 16-bit 3-axis gyroscope, with configurable measurement ranges, on-chip motion detection, and fast startup. Data is transmitted over I2C, enabling real-time acquisition of acceleration, angular velocity, and temperature for motion-sensing applications such as robot attitude sensing, motion detection, wearables, gimbal control, and human-machine interaction.
Features
- BMI270 six-axis inertial sensor
- I2C interface with address switching support
- 16-bit accelerometer and gyroscope sampling
- Configurable measurement ranges and built-in motion detection
- Acceleration, angular velocity, and temperature acquisition
- Suited to attitude sensing and motion detection
Includes
- 1 x Unit DoF6
- 1 x HY2.0-4P Grove Cable (5cm)
Applications
- Robot attitude sensing
- Motion detection
- Wearables
- Gimbal control
- Human-machine interaction
Specifications
| Specification | Parameter |
|---|---|
| IC Model | BMI270 |
| Sensor Type | Six-axis inertial sensor |
| Accelerometer | 16-bit 3-axis accelerometer |
| Accelerometer Range | ±2 g / ±4 g / ±8 g / ±16 g |
| Accelerometer Accuracy | ±20 mg (approx. ±0.02 g) |
| Gyroscope | 16-bit 3-axis gyroscope |
| Gyroscope Range | ±125 / ±250 / ±500 / ±1000 / ±2000 °/s |
| Gyroscope Accuracy | ±0.5 °/s |
| Communication Interface | I2C @ 0x68 / 0x69 (switchable via onboard switch) |
| Product Size | 24.0 x 24.0 x 8.0mm |
| Product Weight | 3.1g |
| Package Size | 138.0 x 93.0 x 7.0mm |
| Gross Weight | 6.6g |
Product Comparison
| Product Comparison | Unit DoF6 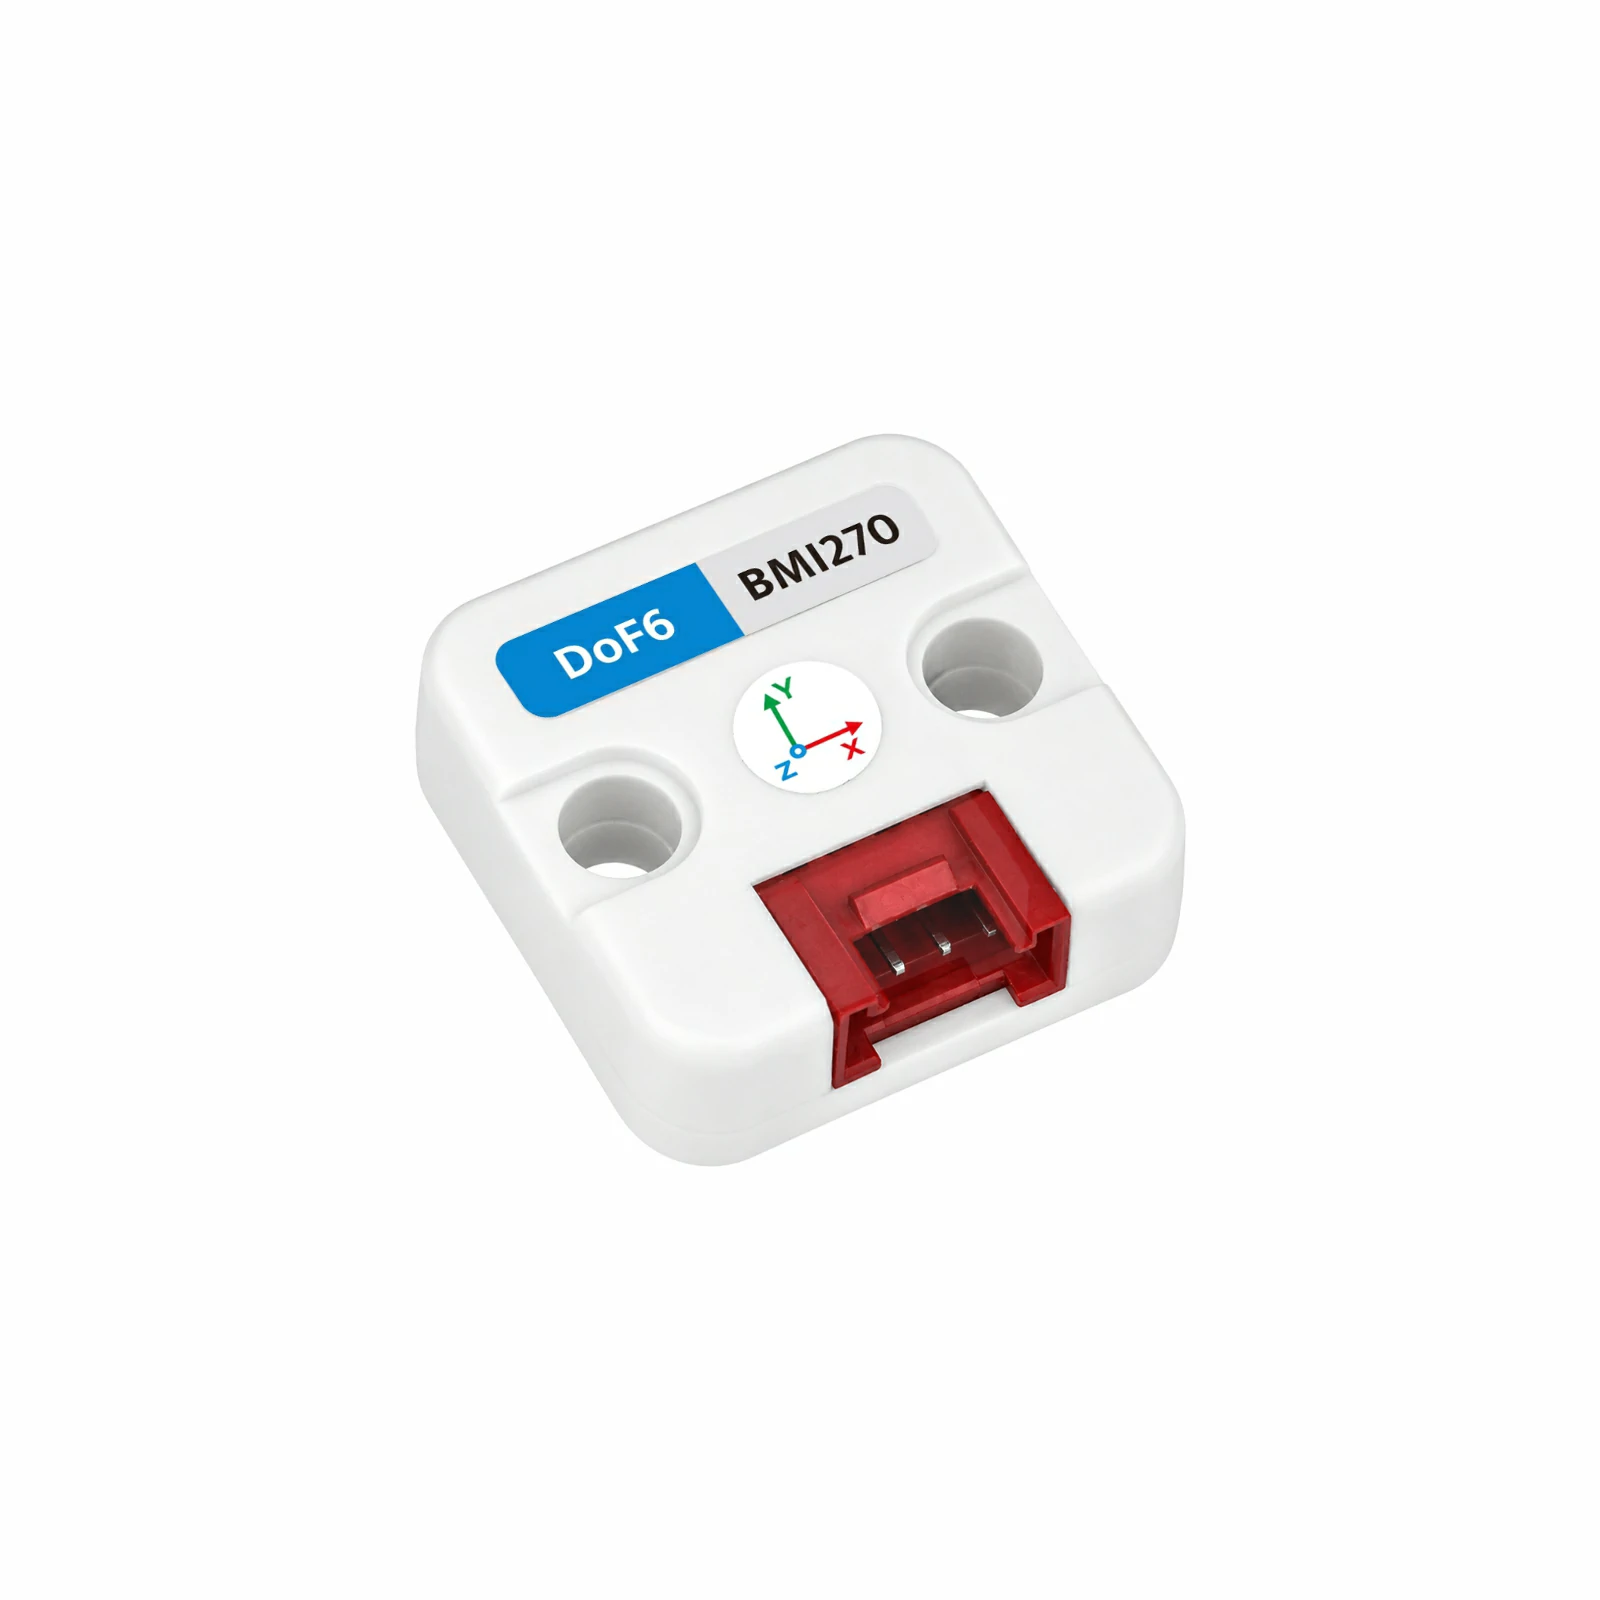
|
Unit DoF9 
|
Unit DoF10 
|
Unit BMM350 
|
|---|---|---|---|---|
| Sensor Combination | BMI270 | BMI270 + BMM350 | BMI270 + BMM350 + SPA06-003 | BMM350 |
| Sensor Type | Six-axis inertial sensor | Six-axis inertial + three-axis geomagnetic sensor | Six-axis inertial + three-axis geomagnetic + barometric pressure sensor | Three-axis geomagnetic sensor |
| Accelerometer | 16-bit 3-axis | 16-bit 3-axis | 16-bit 3-axis | ❌ |
| Gyroscope | 16-bit 3-axis | 16-bit 3-axis | 16-bit 3-axis | ❌ |
| Magnetometer | ❌ | BMM350 (TMR, approx. 0.1 μT) | BMM350 (TMR, approx. 0.1 μT) | BMM350 (TMR, approx. 0.1 μT) |
| Barometric Pressure Sensor | ❌ | ❌ | SPA06-003 | ❌ |
| I2C Address | 0x68 / 0x69 (onboard switch) | BMI270: 0x68 / 0x69 (onboard switch) BMM350: 0x14 |
BMI270: 0x68 / 0x69 (onboard switch) BMM350: 0x14 SPA06-003: 0x76 |
0x14 |
| Main Functions | Acceleration, angular velocity, and temperature acquisition; on-chip motion detection | Acceleration, angular velocity, temperature, and three-axis magnetic field acquisition; on-chip motion detection | Acceleration, angular velocity, temperature, three-axis magnetic field, and pressure acquisition; on-chip motion detection | Three-axis magnetic field acquisition; heading output after calibration |