


Description
Unit 4EncoderMotor Driver is a 4-channel encoder DC motor driver unit featuring an STM32F030C8T6 main controller. It uses an I2C communication interface and provides four DC 5V motor outputs with corresponding A/B encoder inputs, making it suitable for 6-wire encoder geared motors and TT geared motors. The driver supports PWM speed control, forward/reverse control, and closed-loop speed and position control. It integrates an INA199A current-sensing circuit and motor operating voltage detection, enabling real-time monitoring of motor current and voltage.
Two onboard HY2.0-4P Grove ports share the same I2C bus, making it easy to connect additional I2C devices. The I2C address is software-configurable, allowing multiple driver units to be connected to the same bus and expand the number of motor drive channels. The unit accepts an external DC 6 ~ 12V input and, through its onboard DC-DC buck converter, provides a total output capacity of up to DC 5V@8A. This output can power motors and also supply power to a host device through the Grove interface. An onboard programmable RGB LED indicates the device operating status. The unit is suitable for multi-joint robots, wheeled chassis, robotic arms, and similar applications.
Features
- STM32F030C8T6 main controller
- 4-channel encoder motor drive
- Compatible with 6-wire encoder geared motors / TT geared motors (M+ / M- / GND / 5V / EN_B / EN_A)
- Supports 3 ~ 15 PPR encoders
- Motor control
- PWM speed control
- Forward/reverse / stop
- A/B phase counting
- Speed loop / position loop closed-loop control
- Soft start / soft stop
- Sleep
- I2C communication interface
- Default address 0x24, software-configurable (0x08 ~ 0x77)
- 2x HY2.0-4P for sensor / motor drive channel expansion
- Flexible power supply
- 2x external power inputs: DC 6 ~ 12V
- Grove interface power input: DC 5V
- Integrated DC-DC buck converter for motor power and Grove interface output, with a maximum load of DC 5V@8A
- Motor load
- External power supply: maximum single-channel motor load DC 5V@1.2A
- Grove interface power supply: total load of four motors ≤ DC 5V@1A
- Power monitoring
- INA199A motor current detection
- Motor DC 5V operating voltage detection
- Programmable RGB indicator
Includes
- 1 x Unit 4EncoderMotor Driver
- 1 x HY2.0-4P Grove cable (20cm)
- 2 x PH2.0-2P cable (100mm)
- 4 x PH2.0-6P cable (100mm)
Applications
- Multi-joint robot joint drives
- Wheeled chassis / four-wheel-drive smart cars
- Robotic arms and conveyors
- Multi-motor synchronous control
- STEAM education and motor control instruction
Specifications
| Specification | Parameter |
|---|---|
| MCU | STM32F030C8T6 |
| Communication Interface | I2C @ 0x24, software-configurable (0x08 ~ 0x77) |
| Motor Driver | 4-channel DRV8837DSGR H-bridge motor driver |
| Motor Load | Maximum single-channel load: DC 5V@1.2A (external input supply DC 6 ~ 12V) |
| Motor Operating Modes | PWM speed control, forward/reverse, soft start / soft stop, speed loop, position loop, sleep |
| Encoder | 4-channel AB encoder input, supports 3 ~ 15 PPR |
| Encoder Motor Interface | 4x PH2.0-6P, compatible with 6-wire encoder geared motors / TT geared motors (M+ / M- / GND / 5V / EN_B / EN_A) |
| Power Supply | 2x PH2.0-2P external DC power input: DC 6 ~ 12V HY2.0-4P Grove power input: DC 5V |
| Current Detection | INA199A |
| RGB LED | 1x WS2812C-2020 |
| Product Size | 56.5 x 24.0 x 12.8mm |
| Product Weight | 10.0g |
| Package Size | 138.0 x 93.0 x 21.0mm |
| Gross Weight | 25.5g |
Product Comparison
| Product Compare | Unit 4EncoderMotor Driver 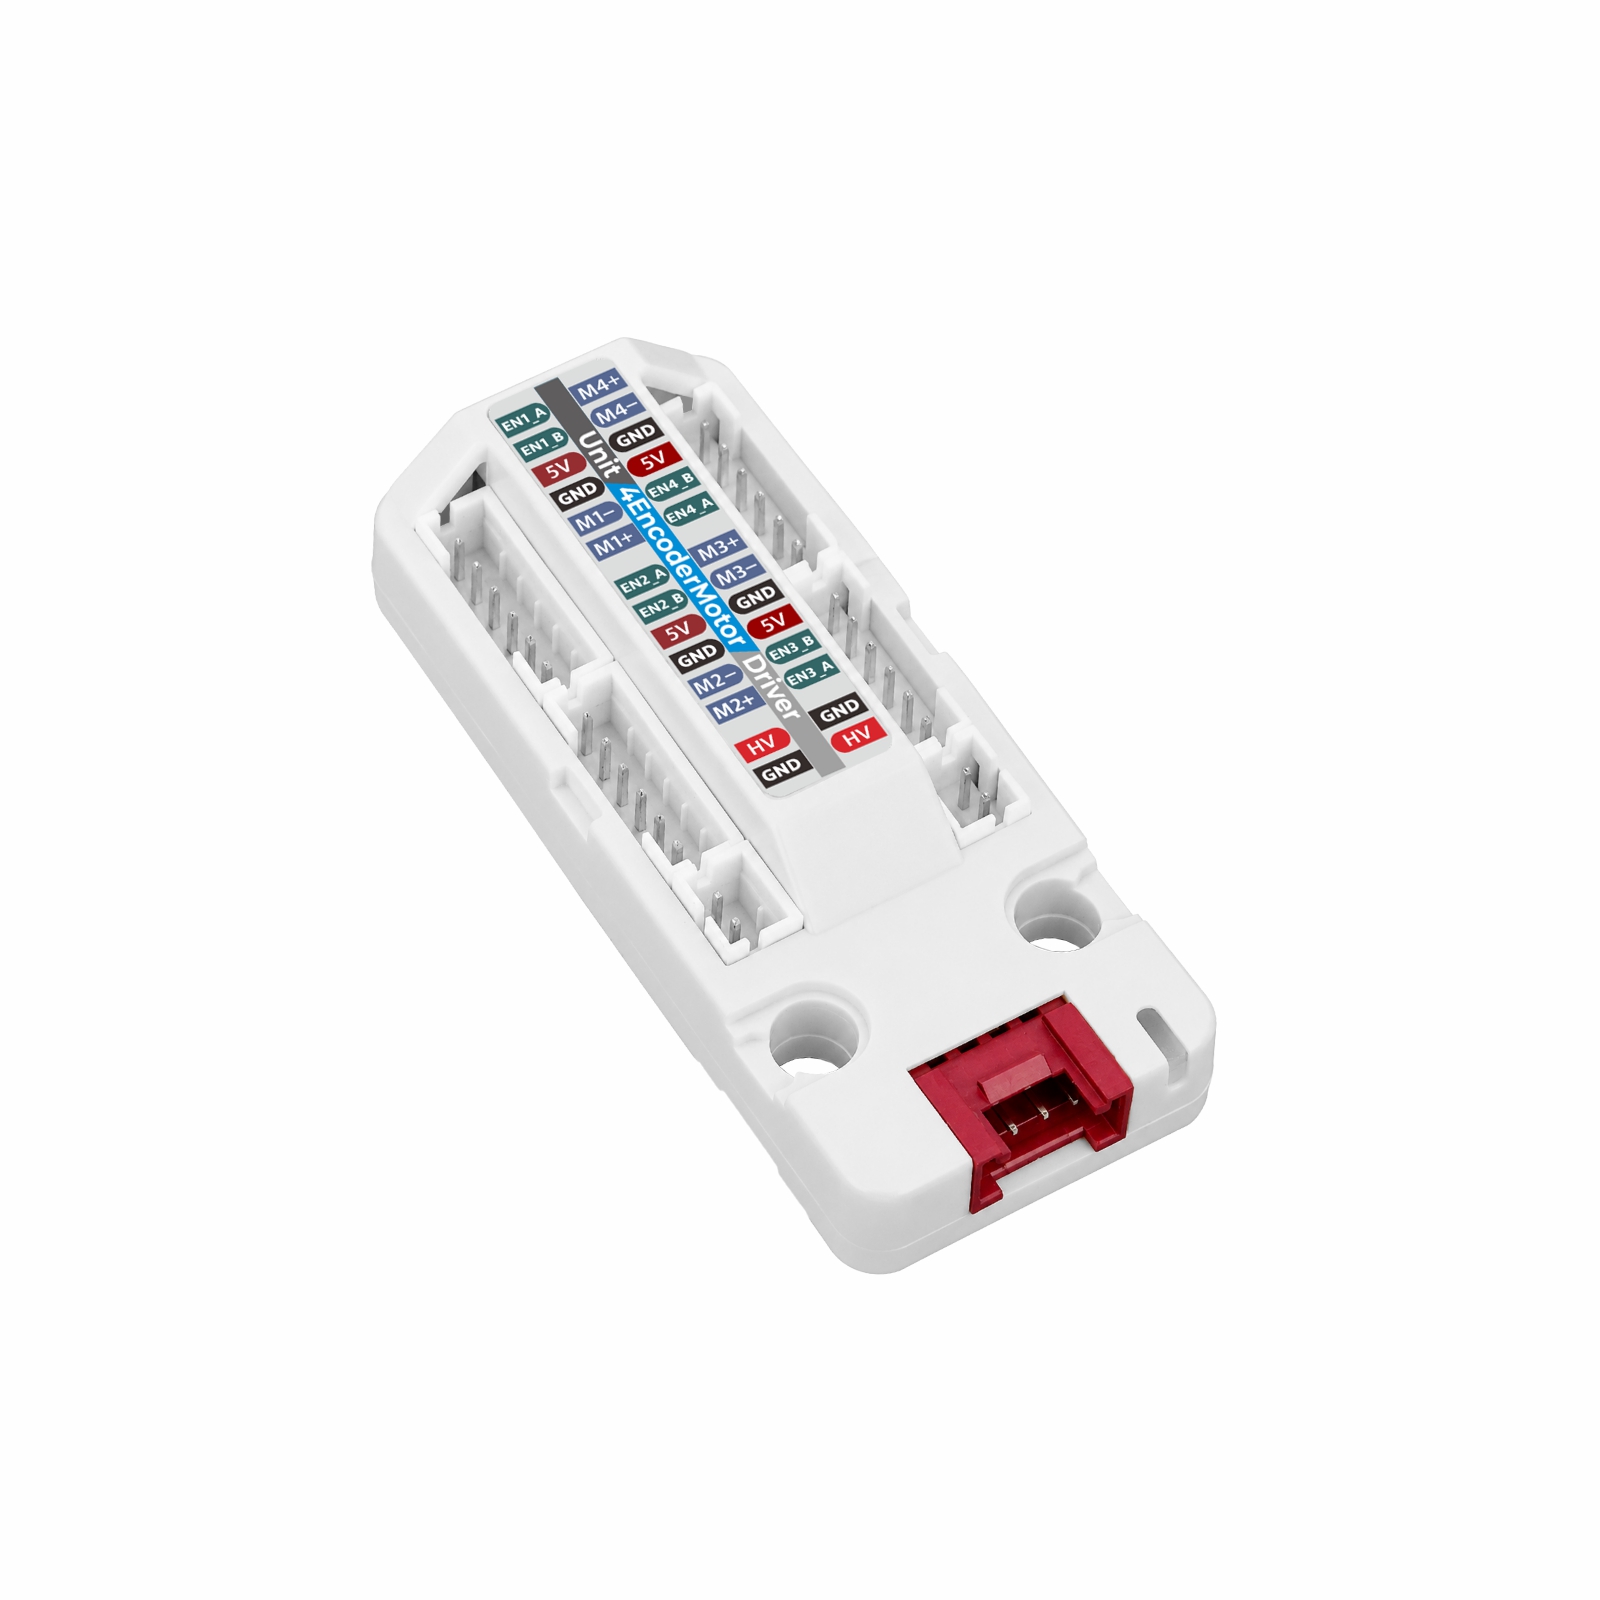
|
Unit EncoderMotor Driver 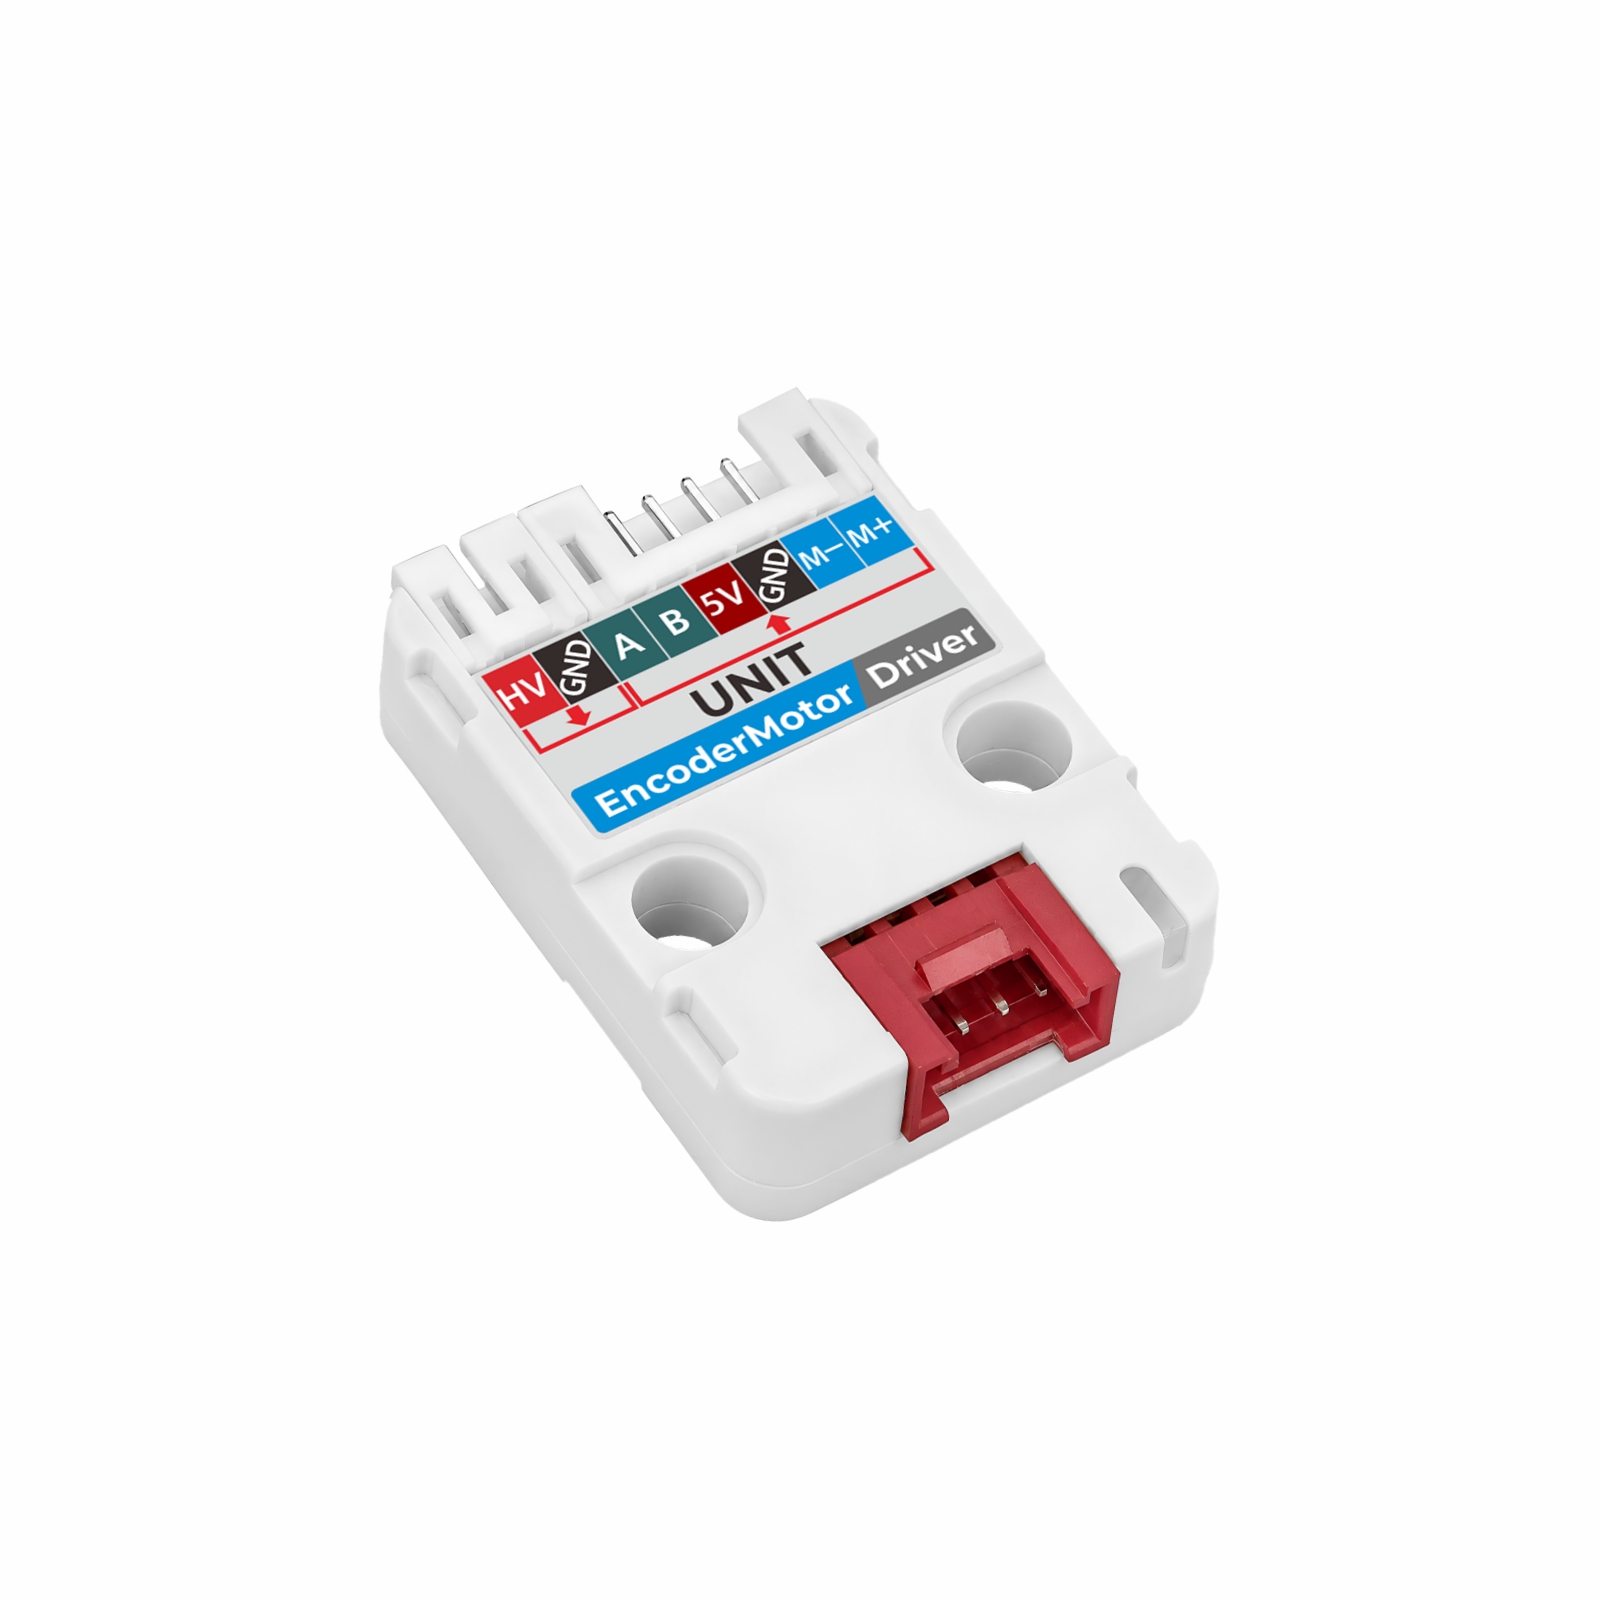
|
|---|---|---|
| Communication Interface | I2C | I2C |
| Channel Count | 4-channel encoder motor drive | 1-channel encoder motor drive |
| Motor Driver | 4x DRV8837DSGR | 1x DRV8837DSGR |
| Main Controller | STM32F030C8T6 | STM32G031G8U6 |
| Encoder Motor Interface | 4x PH2.0-6P | 1x PH2.0-6P |
| External Power Input | DC 6 ~ 12V (2x PH2.0-2P) | DC 6 ~ 12V (1x PH2.0-2P) |
| Motor Load Capacity | Single-channel DC 5V@1.2A | DC 5V@1.2A |
| Current Detection | INA199 | INA199 |
| Grove Interface | 2 x HY2.0-4P | 1 x HY2.0-4P |