


Description
Unit DoF10 is a 10-axis attitude sensing unit that integrates a six-axis inertial sensor, a three-axis magnetometer, and a barometric pressure sensor. It features the low-power BMI270 IMU, the BMM350 three-axis magnetometer, and the SPA06-003 pressure sensor. The BMI270 integrates a 16-bit 3-axis accelerometer and a 16-bit 3-axis gyroscope, with configurable measurement ranges and on-chip motion event detection. The BMM350 uses TMR (tunnel magnetoresistance) technology for three-axis magnetic field measurement, achieving approximately 0.1 μT resolution and excellent temperature stability. The SPA06-003 measures pressure, temperature, and relative altitude.
Unit DoF10 outputs acceleration, angular velocity, temperature, three-axis magnetic field, and pressure data in real time, making it suitable for robot attitude estimation, heading detection, electronic compass, motion tracking, barometric altimetry, floor change detection, drones, and other applications.
Features
- Integrated six-axis inertial, three-axis magnetic, and barometric pressure sensors
- I2C communication interface
- BMI270 with 16-bit sampling and motion detection
- BMM350 with TMR technology and high magnetic field resolution
- SPA06-003 for pressure, temperature, and altitude measurement
- Supports various attitude, heading, and altitude applications
Includes
- 1 x Unit DoF10
- 1 x HY2.0-4P Grove Cable (5cm)
Applications
- Robot attitude sensing
- Heading detection
- Electronic compass
- Motion tracking
- Barometric altimetry
- Floor change detection
- Drones
Specifications
| Specification | Parameter |
|---|---|
| IC Model | BMI270 + BMM350 + SPA06-003 |
| Sensor Type | Six-axis inertial, three-axis magnetic, and barometric pressure sensor |
| Accelerometer | 16-bit 3-axis accelerometer |
| Accelerometer Range | ±2 g / ±4 g / ±8 g / ±16 g |
| Accelerometer Accuracy | ±20 mg (approx. ±0.02 g) |
| Gyroscope | 16-bit 3-axis gyroscope |
| Gyroscope Range | ±125 / ±250 / ±500 / ±1000 / ±2000 °/s |
| Gyroscope Accuracy | ±0.5 °/s |
| Magnetometer | BMM350 three-axis magnetometer |
| Magnetic Field Range | X/Y/Z axes: ±2000 μT (typical on each axis) |
| Magnetic Field Resolution | approx. 0.1 μT |
| Barometric Pressure Sensor | SPA06-003 |
| Pressure Measurement Range | 300 ~ 1100 hPa |
| Absolute Pressure Accuracy | ±0.3 hPa (typical) |
| Relative Pressure Accuracy | ±0.03 hPa (typical) |
| Temperature Measurement Range | -40 ~ +85 °C |
| Temperature Accuracy | ±1 °C (typical) |
| Communication Interface | I2C |
| BMI270 I2C Address | I2C @ 0x68 / 0x69 (switchable via onboard switch) |
| BMM350 I2C Address | I2C @ 0x14 |
| SPA06-003 I2C Address | I2C @ 0x76 |
| Product Size | 24.0 x 24.0 x 8.0mm |
| Product Weight | 3.1g |
| Package Size | 138.0 x 93.0 x 7.0mm |
| Gross Weight | 6.6g |
Product Comparison
| Product Comparison | Unit DoF6 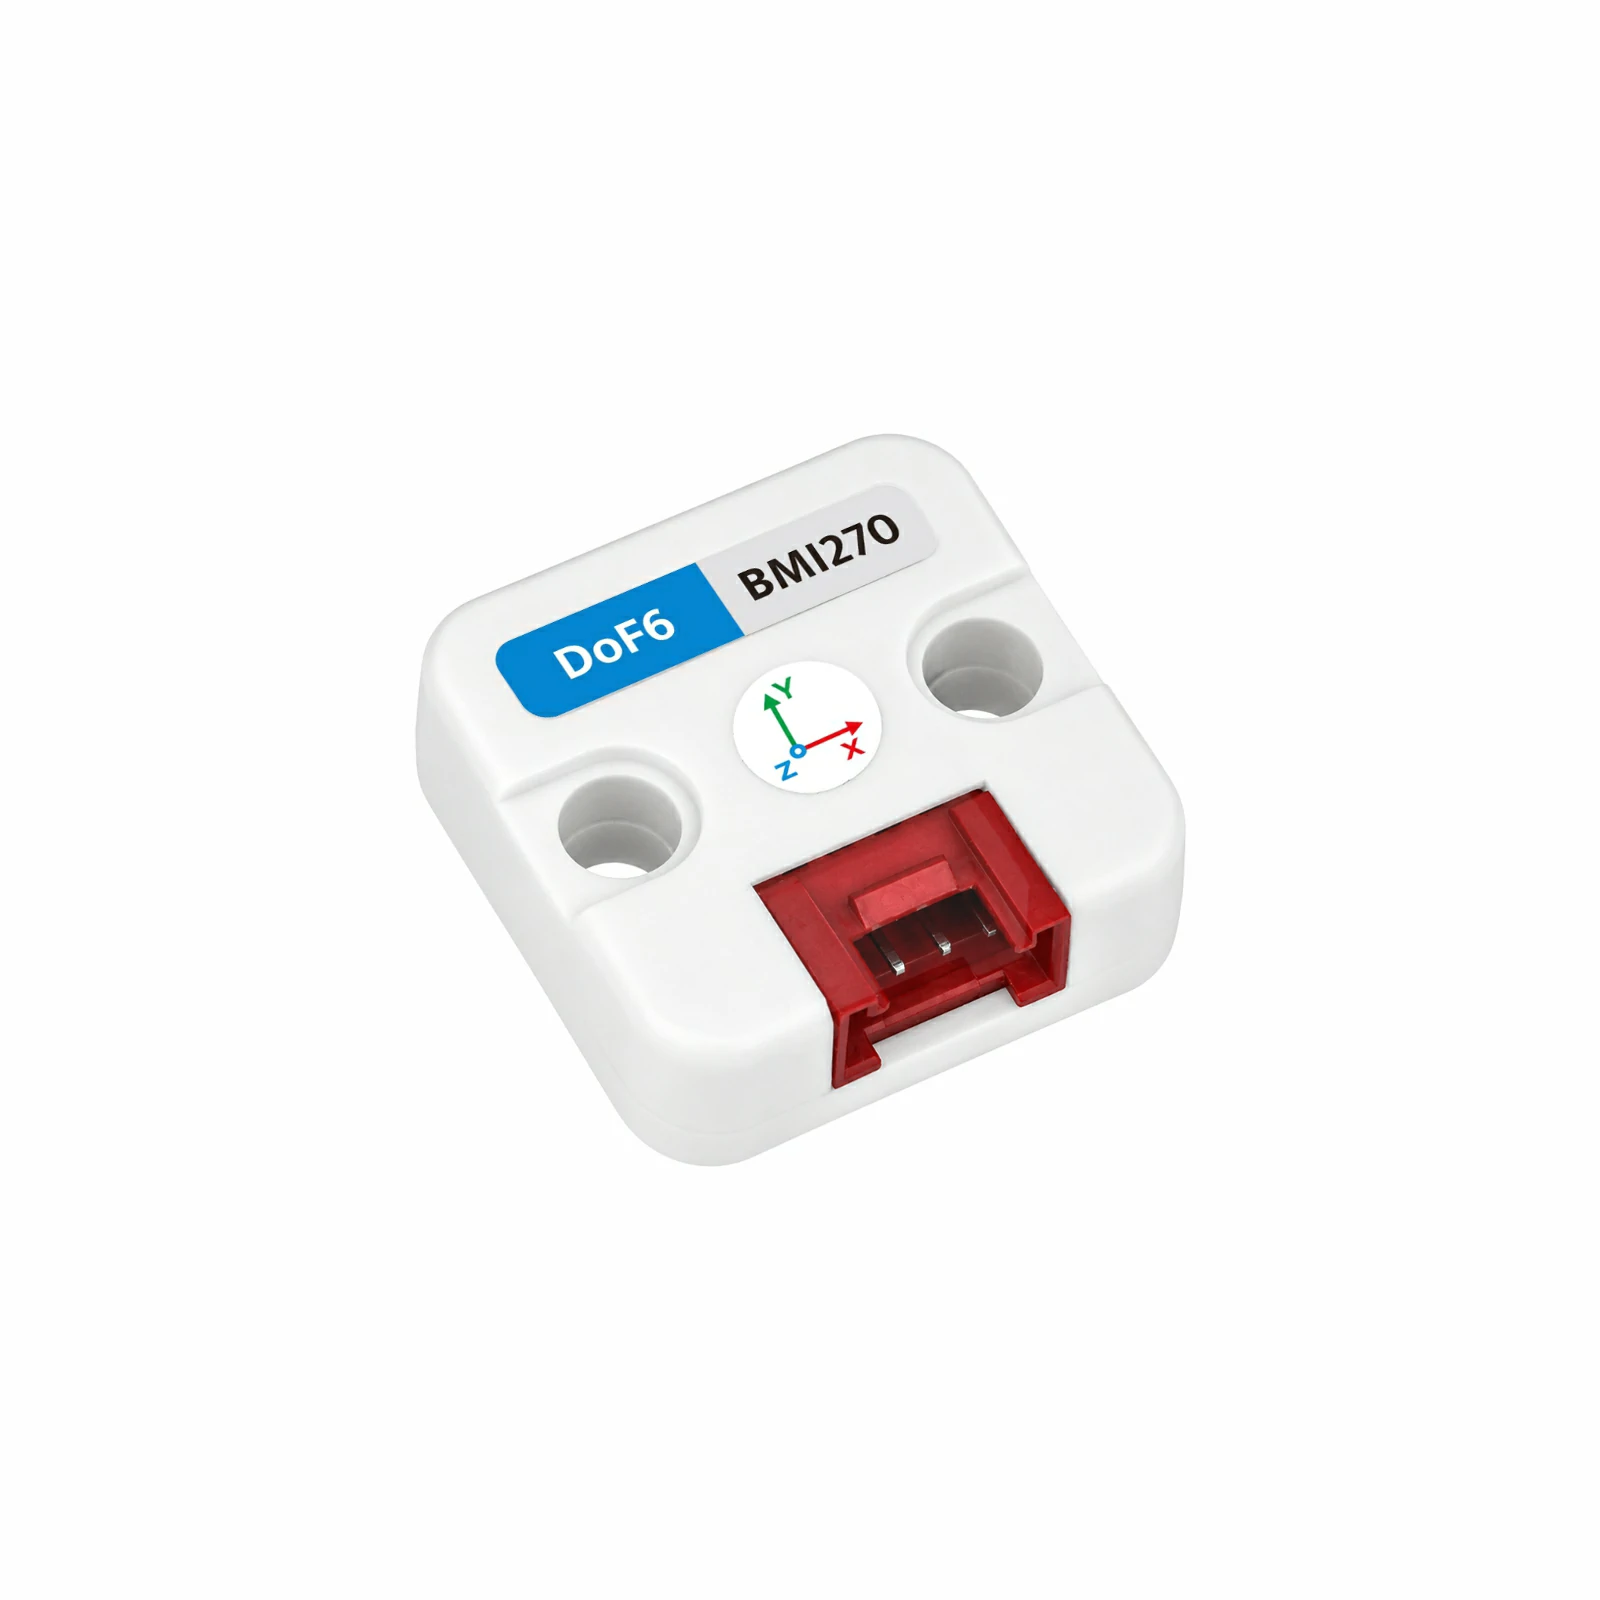
|
Unit DoF9 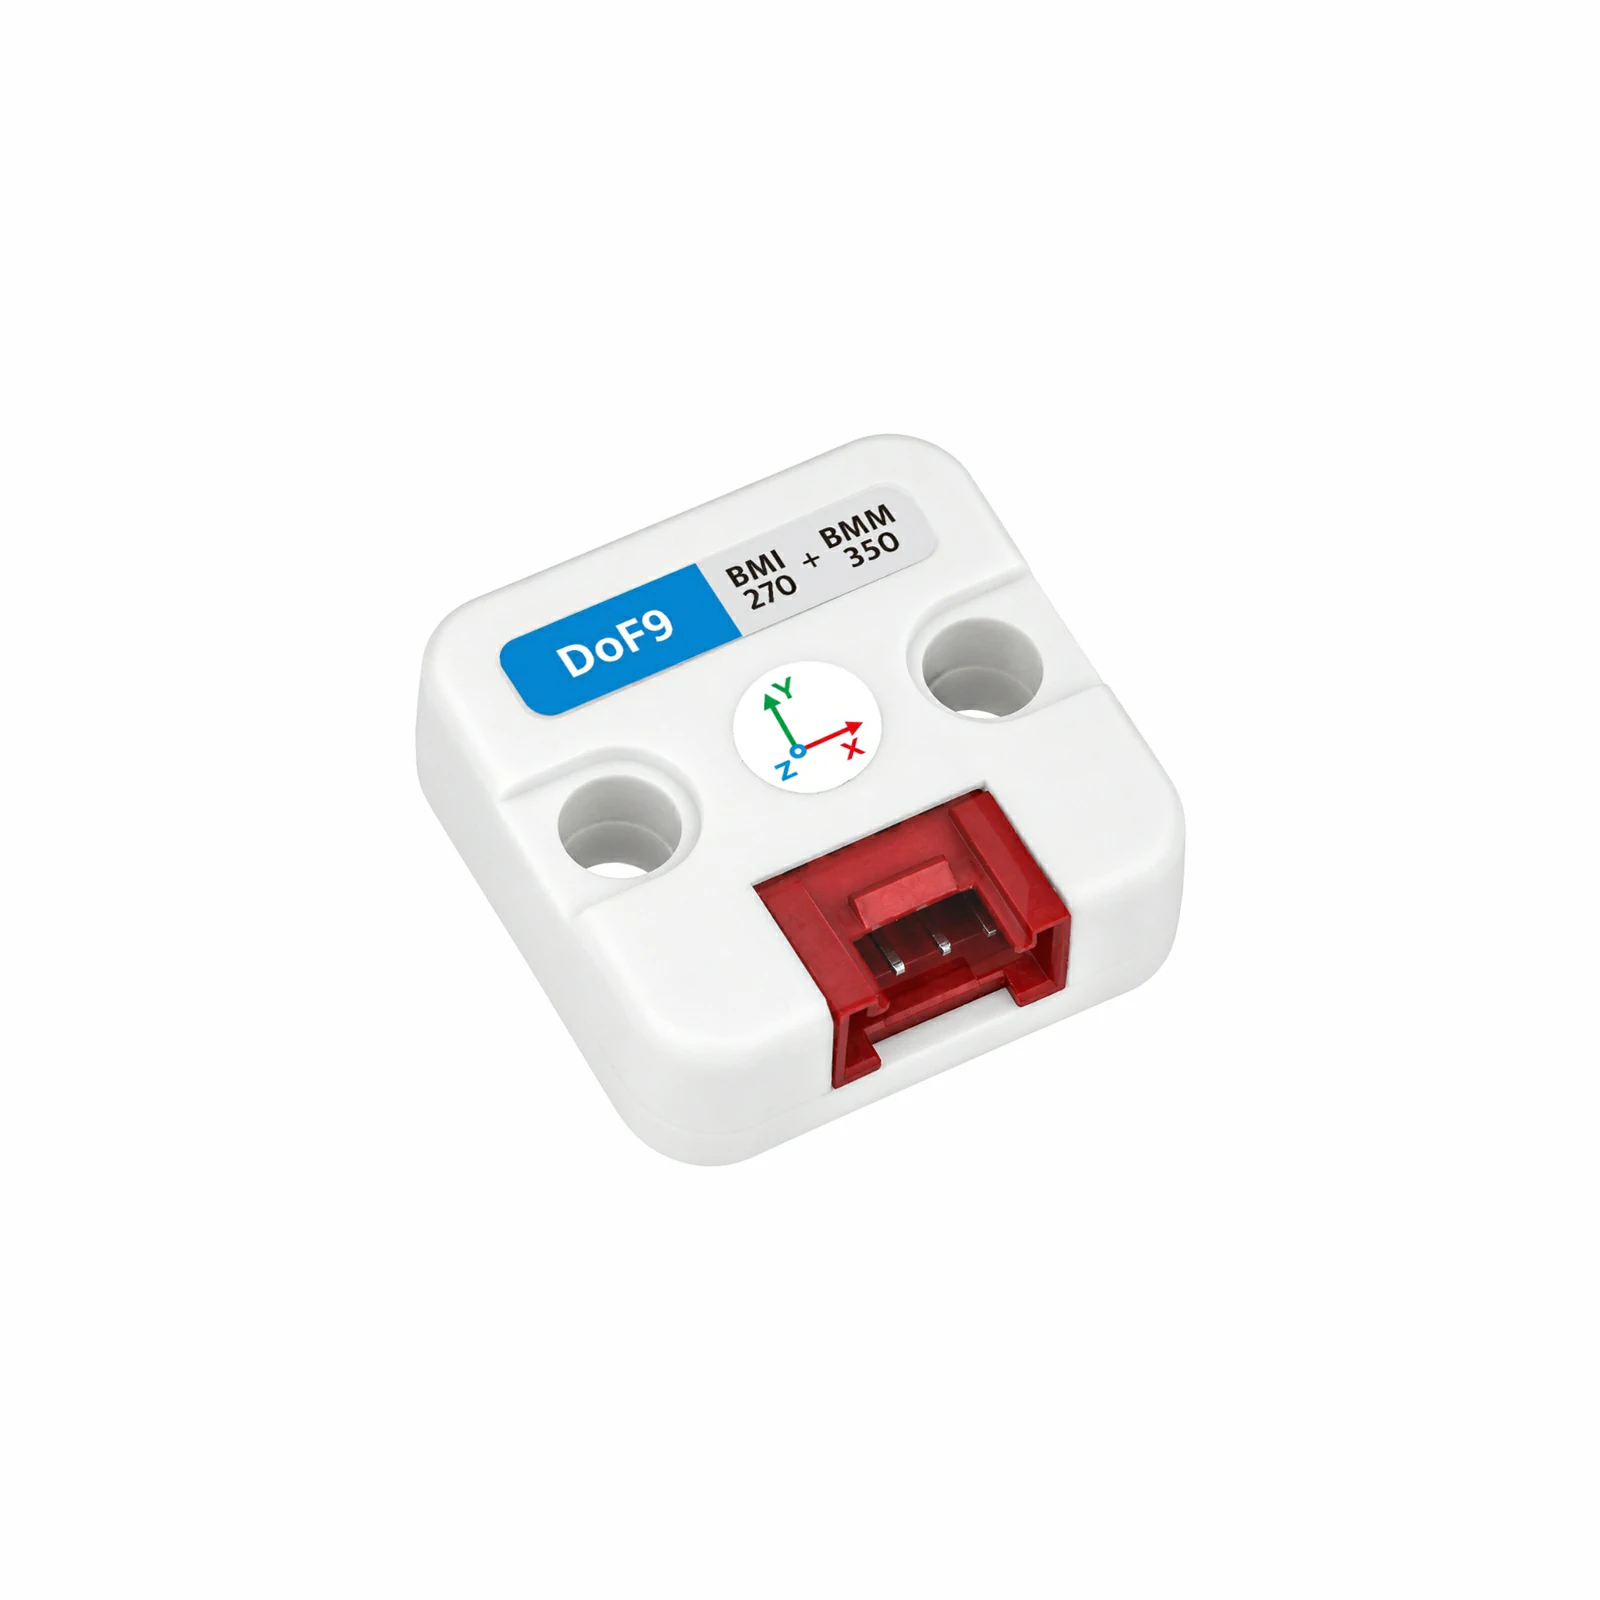
|
Unit DoF10 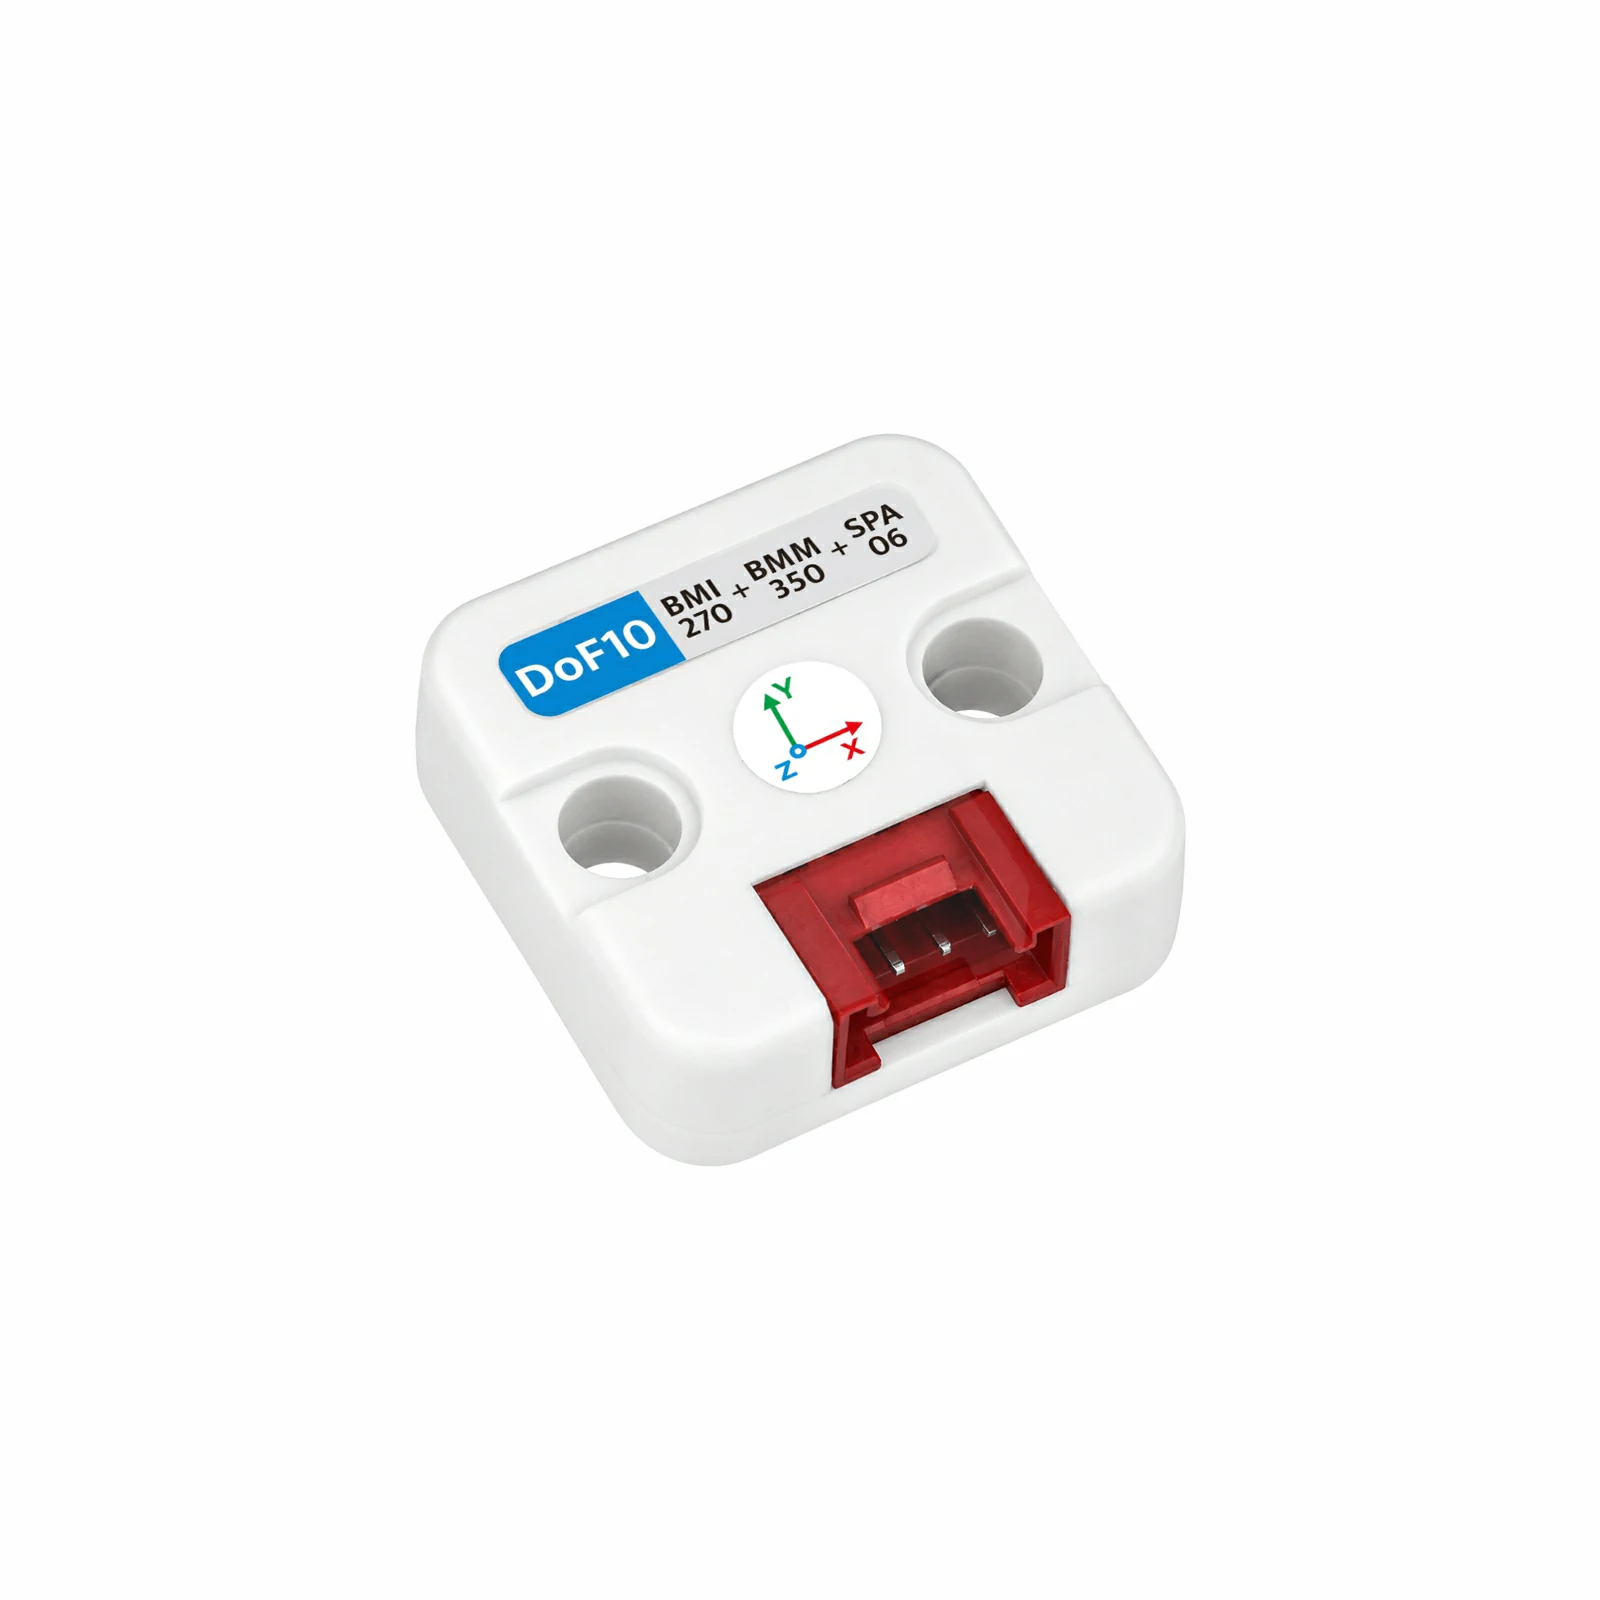
|
Unit BMM350 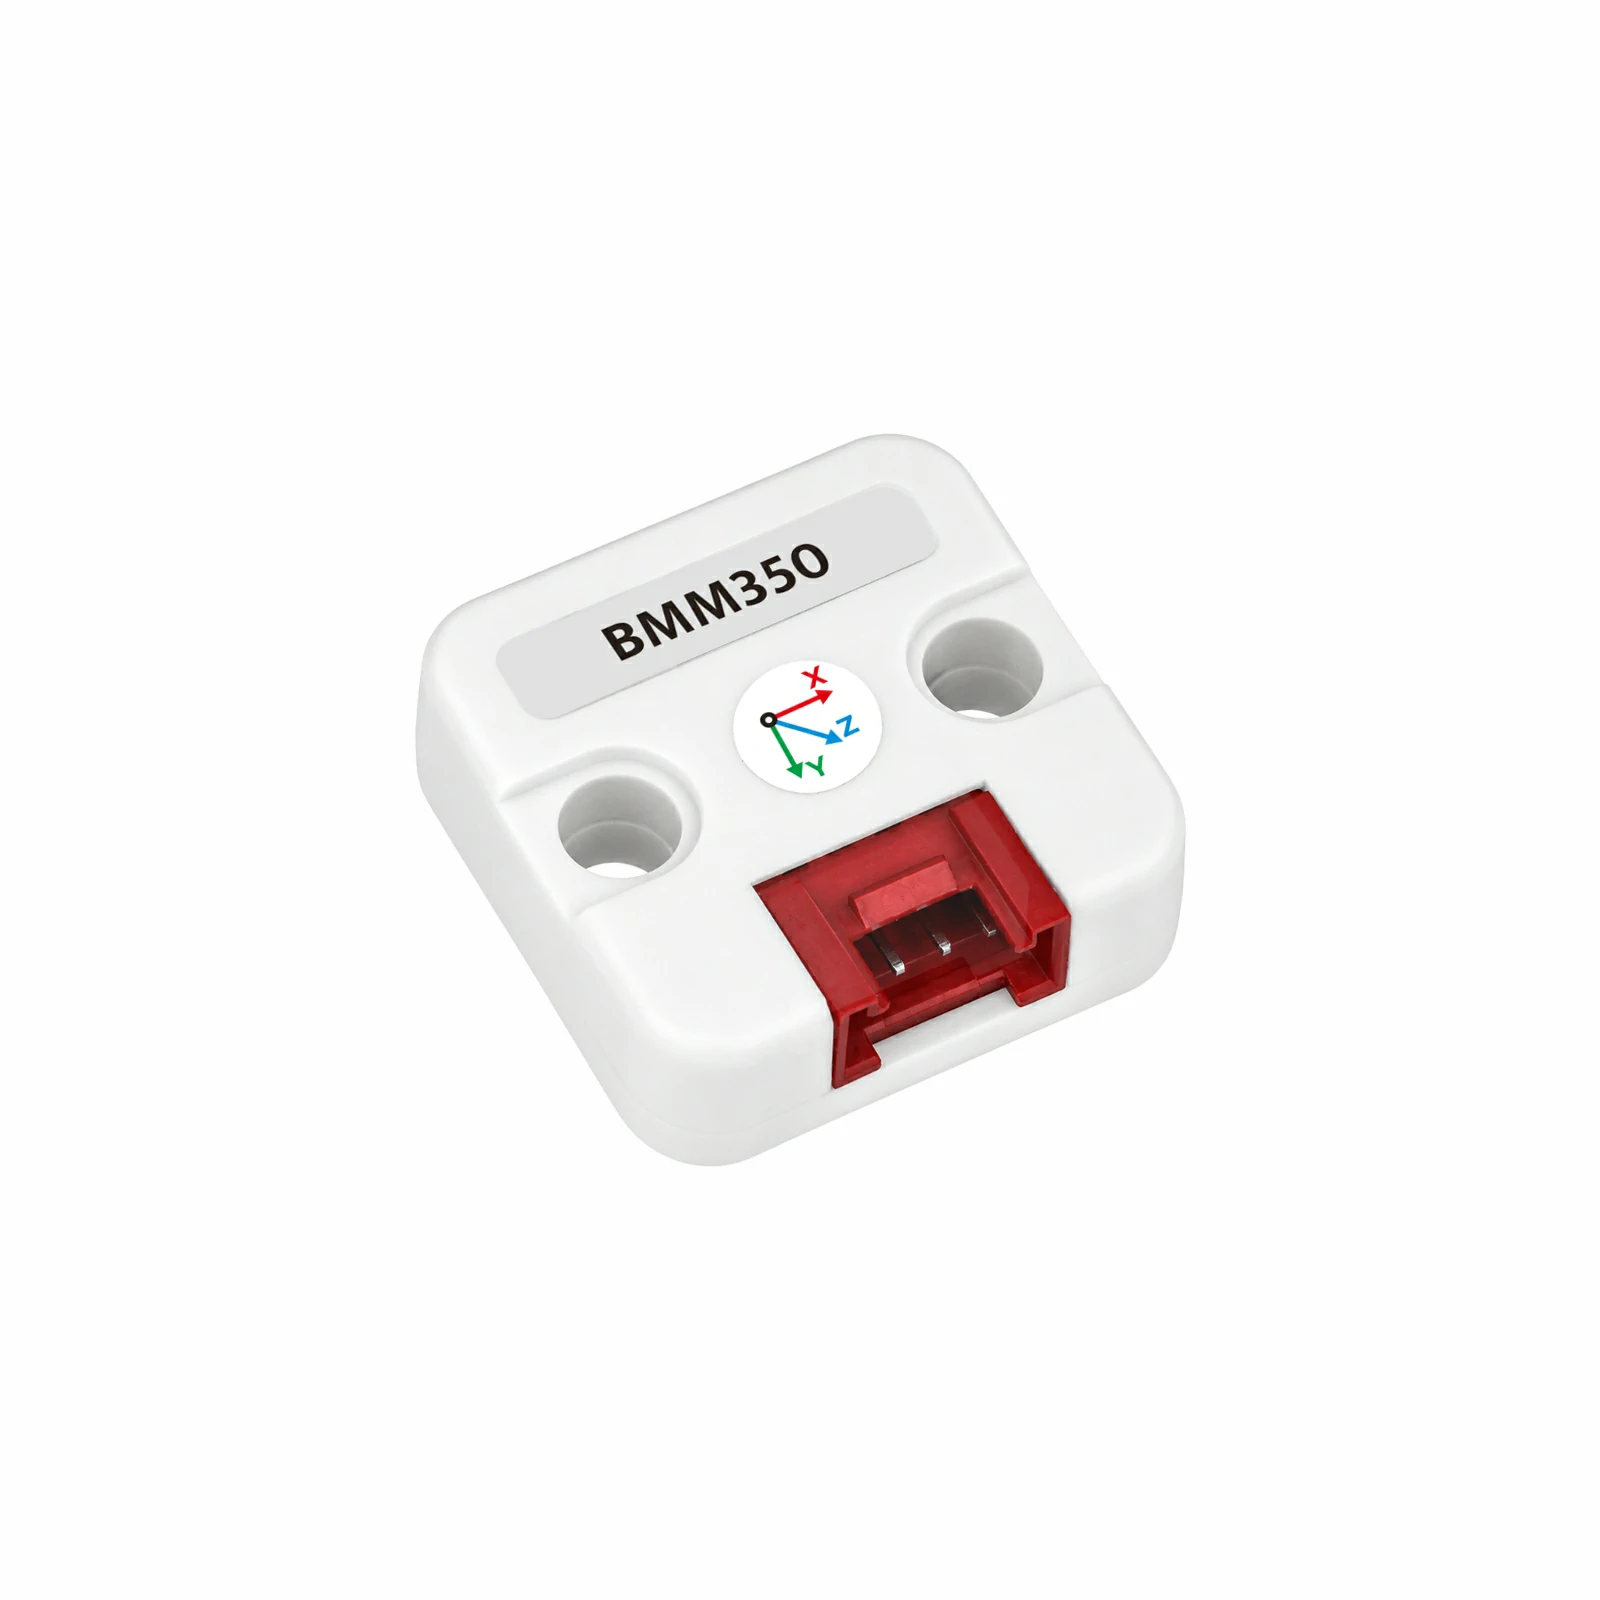
|
|---|---|---|---|---|
| Sensor Combination | BMI270 | BMI270 + BMM350 | BMI270 + BMM350 + SPA06-003 | BMM350 |
| Sensor Type | Six-axis inertial sensor | Six-axis inertial + three-axis geomagnetic sensor | Six-axis inertial + three-axis geomagnetic + barometric pressure sensor | Three-axis geomagnetic sensor |
| Accelerometer | 16-bit 3-axis | 16-bit 3-axis | 16-bit 3-axis | ❌ |
| Gyroscope | 16-bit 3-axis | 16-bit 3-axis | 16-bit 3-axis | ❌ |
| Magnetometer | ❌ | BMM350 (TMR, approx. 0.1 μT) | BMM350 (TMR, approx. 0.1 μT) | BMM350 (TMR, approx. 0.1 μT) |
| Barometric Pressure Sensor | ❌ | ❌ | SPA06-003 | ❌ |
| I2C Address | 0x68 / 0x69 (onboard switch) | BMI270: 0x68 / 0x69 (onboard switch) BMM350: 0x14 |
BMI270: 0x68 / 0x69 (onboard switch) BMM350: 0x14 SPA06-003: 0x76 |
0x14 |
| Main Functions | Acceleration, angular velocity, and temperature acquisition; on-chip motion detection | Acceleration, angular velocity, temperature, and three-axis magnetic field acquisition; on-chip motion detection | Acceleration, angular velocity, temperature, three-axis magnetic field, and pressure acquisition; on-chip motion detection | Three-axis magnetic field acquisition; heading output after calibration |